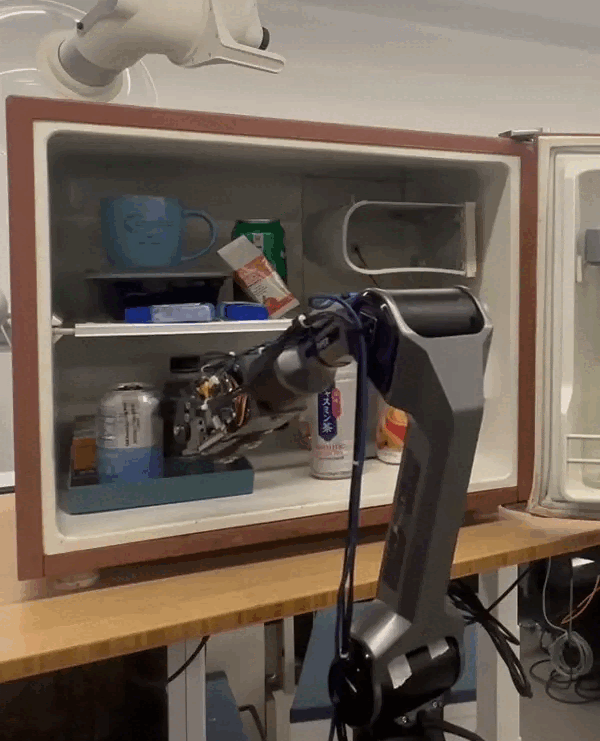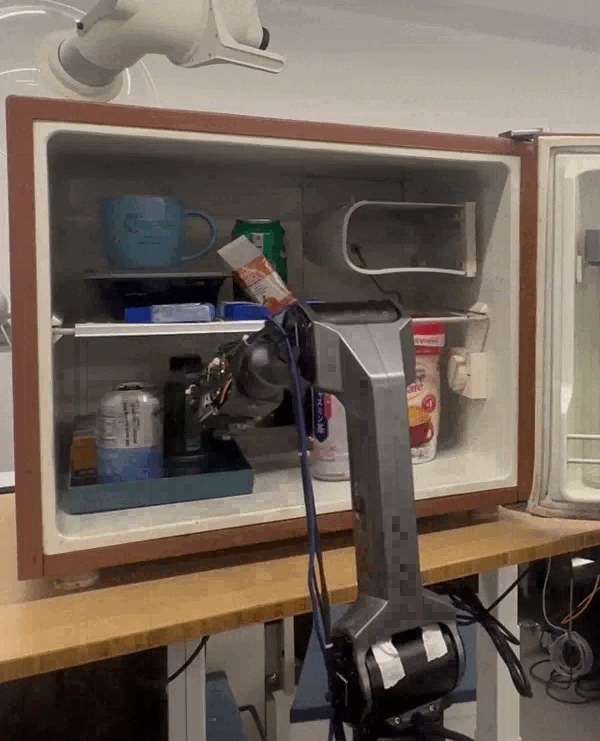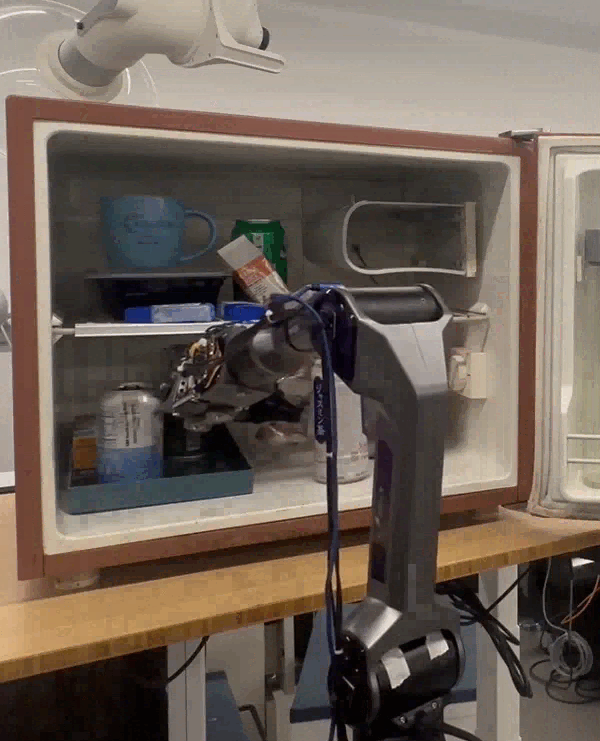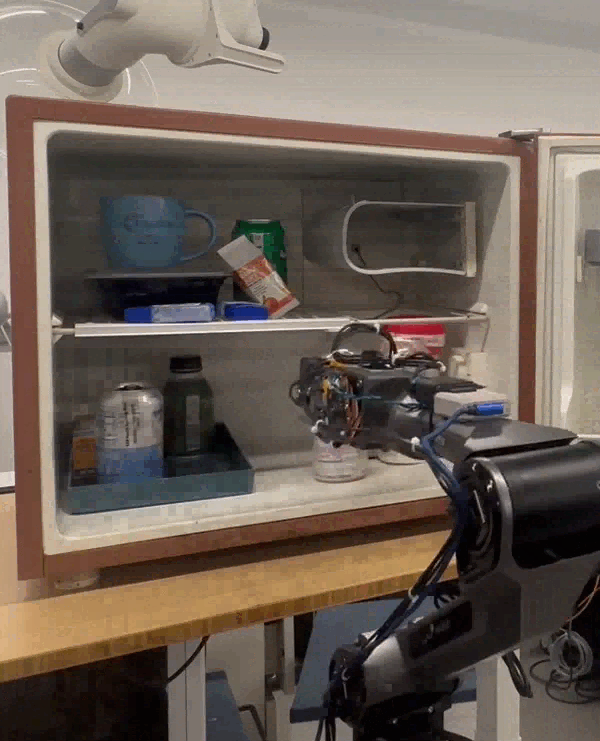
Policy Learning Results
Behavior-cloning success on the constrained AgileX task and the contact-rich UR3e task
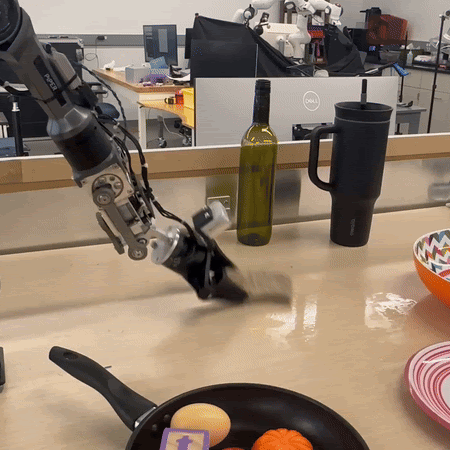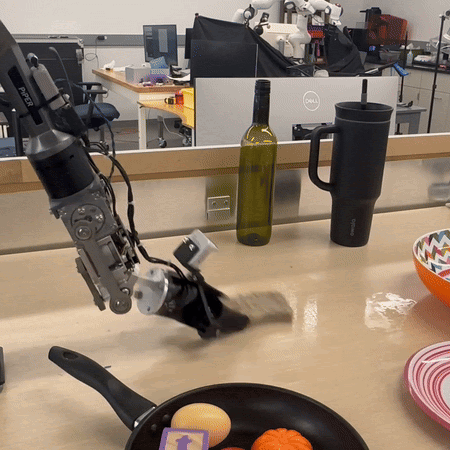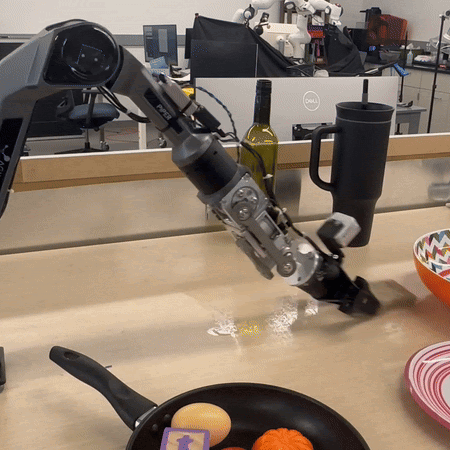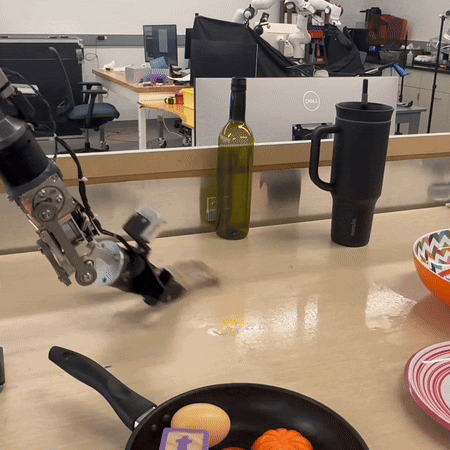
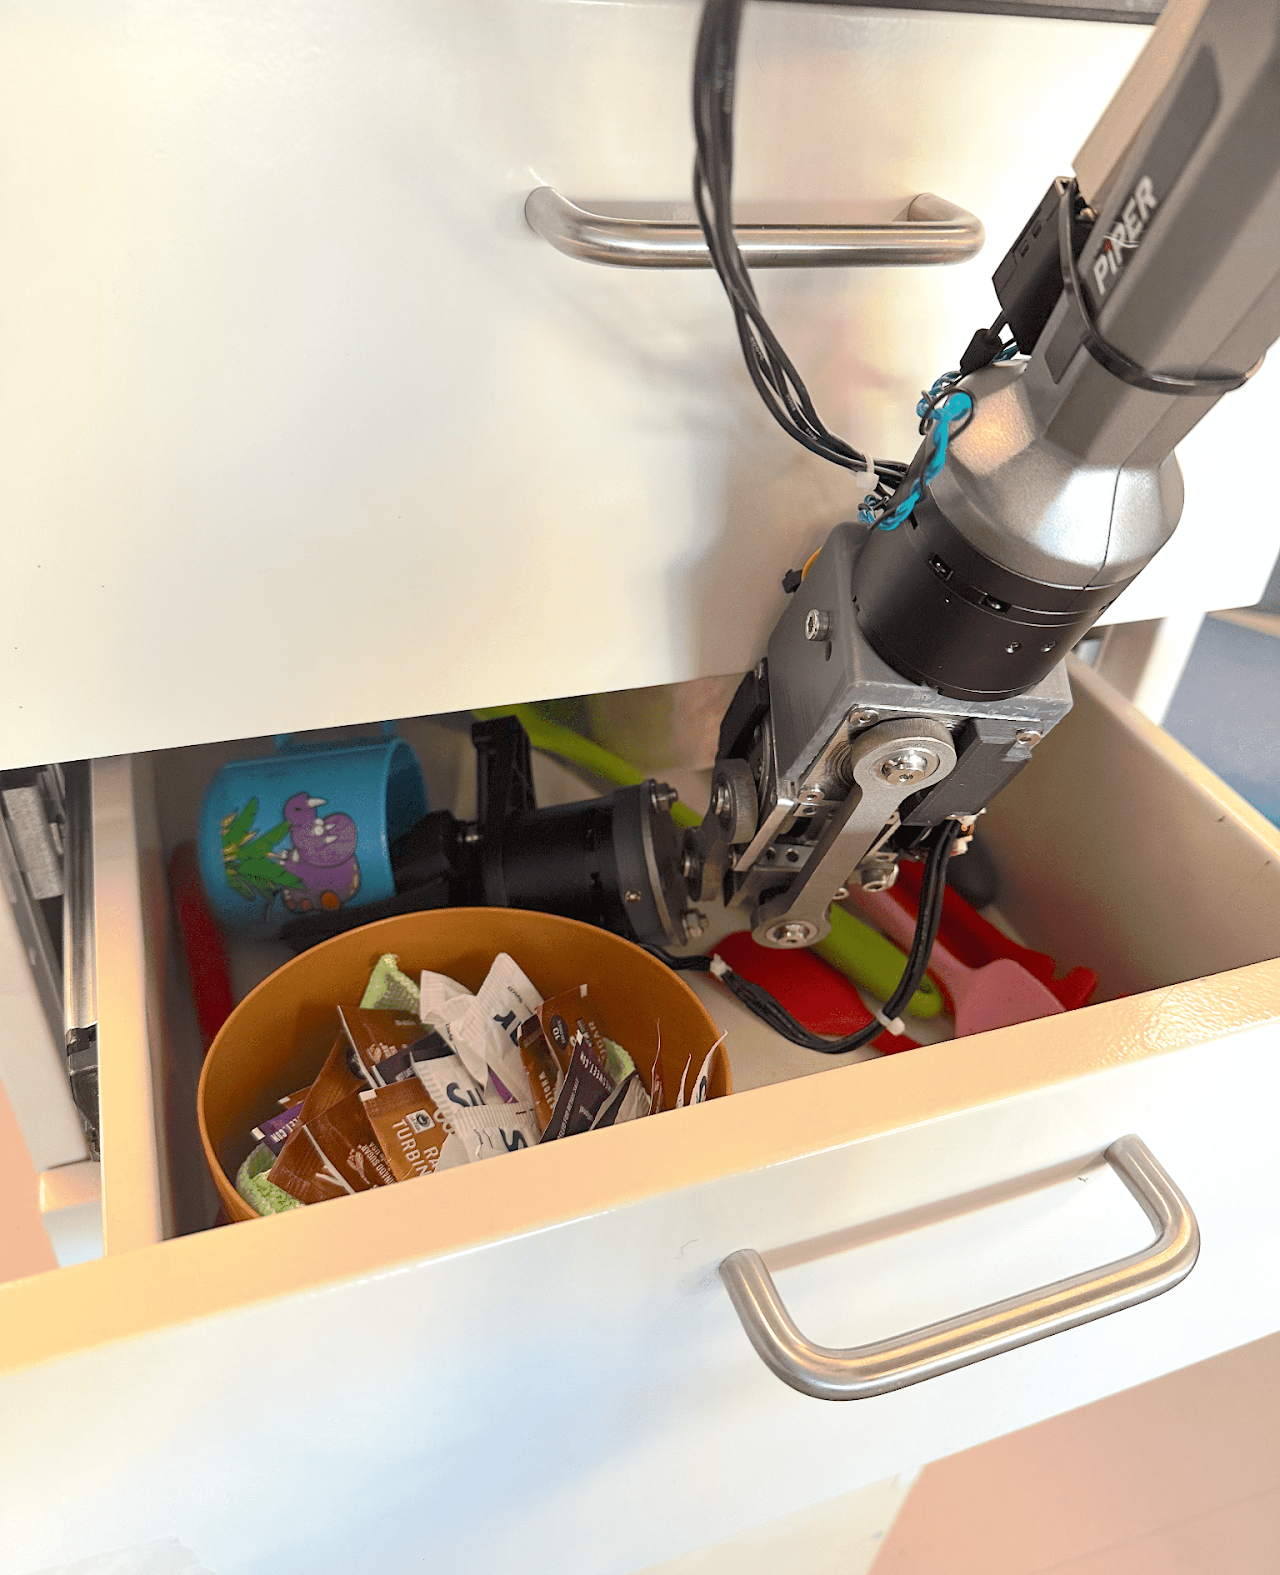
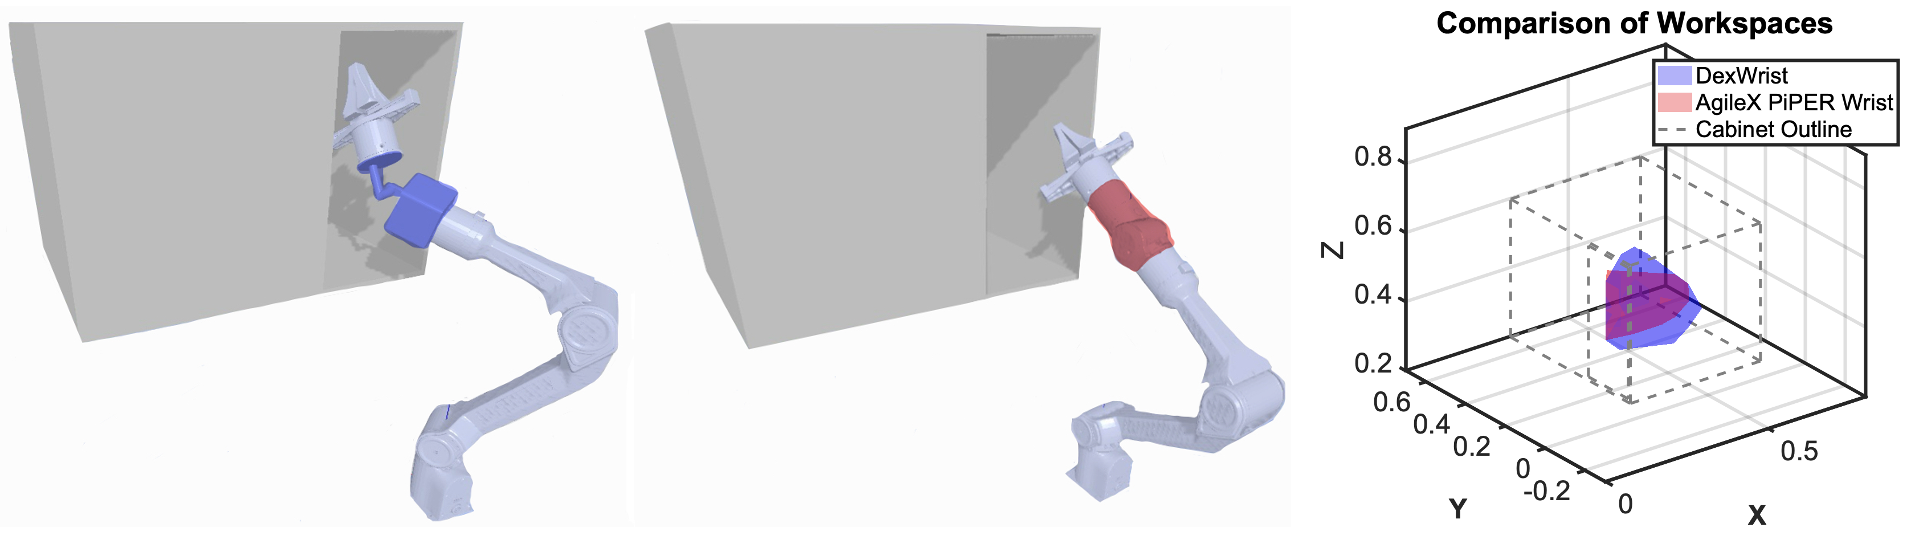
DexWrist achieved 50–76% relative improvement in policy success rates on the AgileX and UR3e
Wiping Under a Strong Compliant-Control Baseline
To confirm that the wiping improvement reflects the wrist hardware rather than the UR3e's admittance
controller, we repeat the evaluation on a torque-controlled Franka FR3, whose joint-impedance control already
performs the task well. Success is saturated for both conditions (stock 19/20, DexWrist 20/20), so completion
time is the informative metric: with DexWrist, the policy completes the task 1.43× faster under
the same controller and action space.
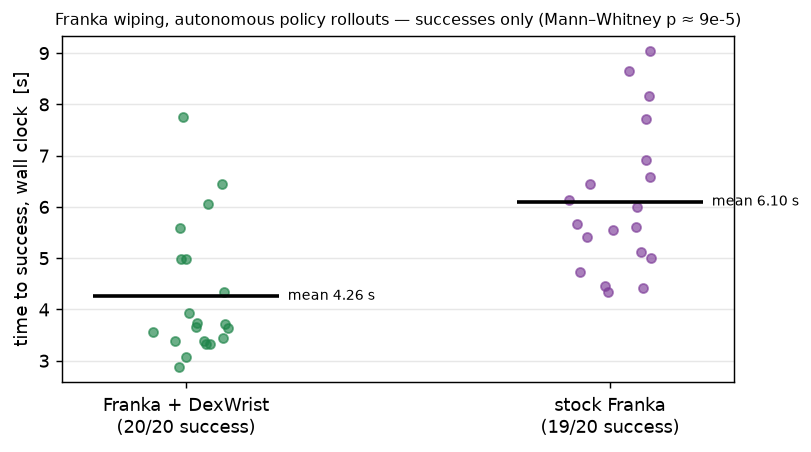
Full experiment, including the teleoperation-effort comparison, on the
Franka wiping page.