RA-L 2026 · arXiv:2507.01008

DexWrist: A Robotic Wrist for Constrained and Dynamic Manipulation

Improbable AI Lab, Massachusetts Institute of Technology

Motivation

The spatial orientation of an end-effector such as a hand or a gripper is closely tied to its ability to perform a desired task [...] Yet both the academic and industrial research communities have tended to place more focus on hand/gripper development than that of wrist systems.

Recent prosthetics investigations, however, have shown that increased dexterity in wrist prostheses may contribute more to manipulation capacity than a highly dexterous terminal device with limited wrist capability. [1]
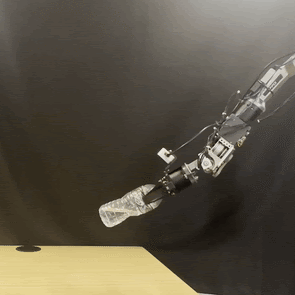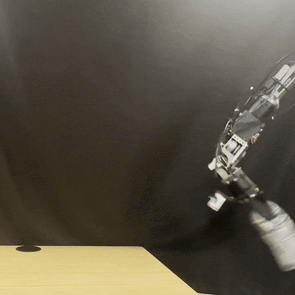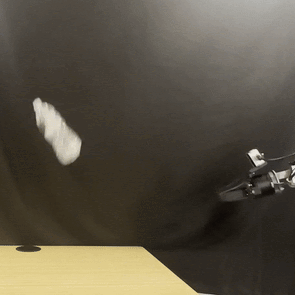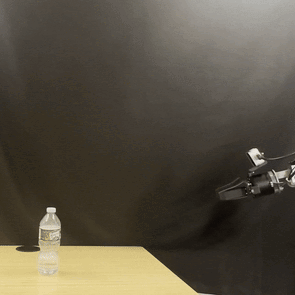
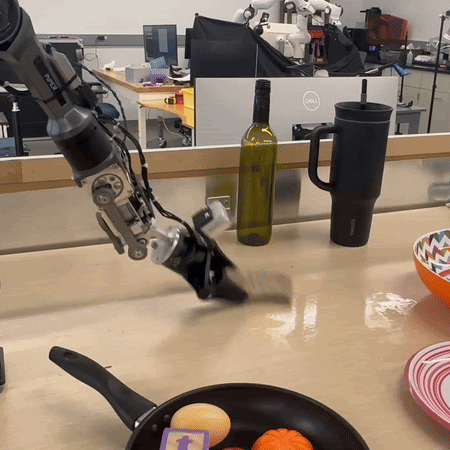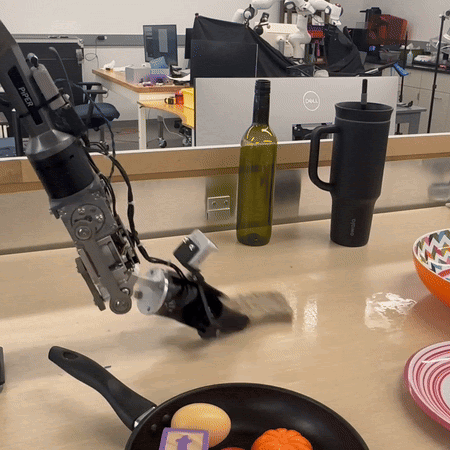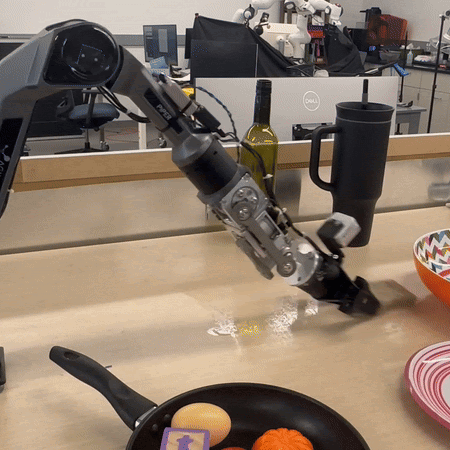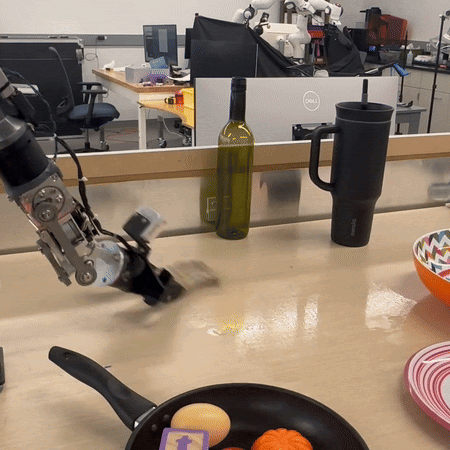
DexWrist is fast.Measured no-load speed: 96.6 ± 9.4 rpm.

DexWrist enables highly dynamic and contact-rich tasks

Bottle Flip

Demonstration (1x Speed)

Agile Wipe

Demonstration (1x Speed)

Robust Wipe

Autonomous (1x Speed)

(1X Speed) DexWrist performs highly dynamic tasks with human-level wrist dexterity.

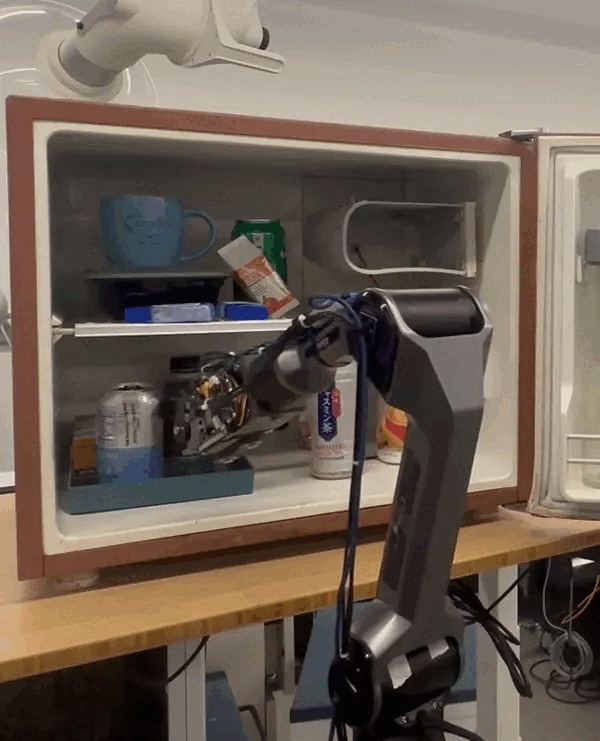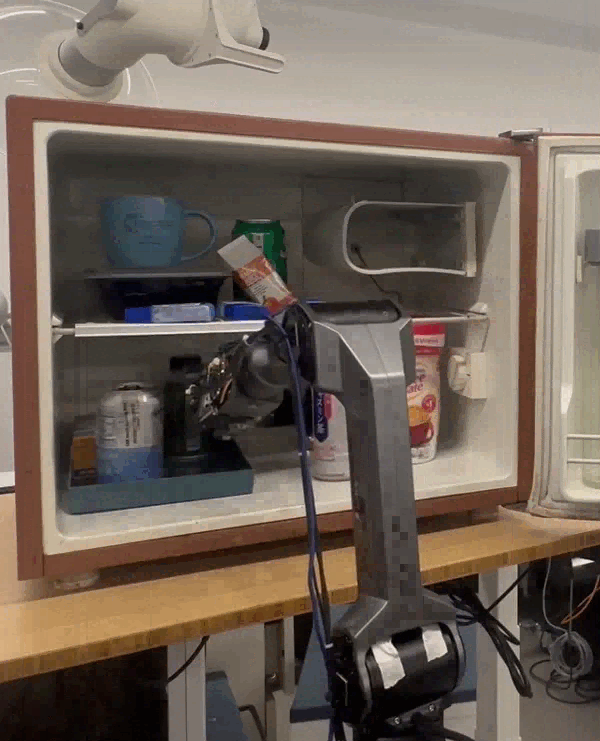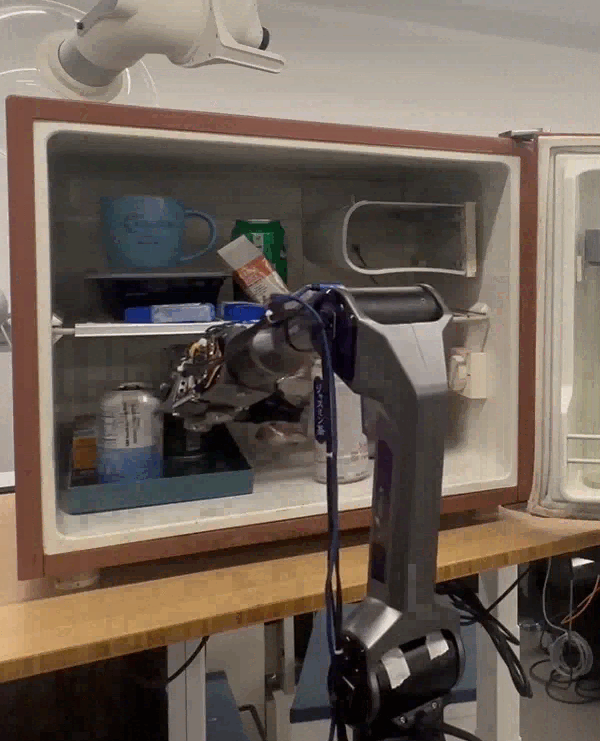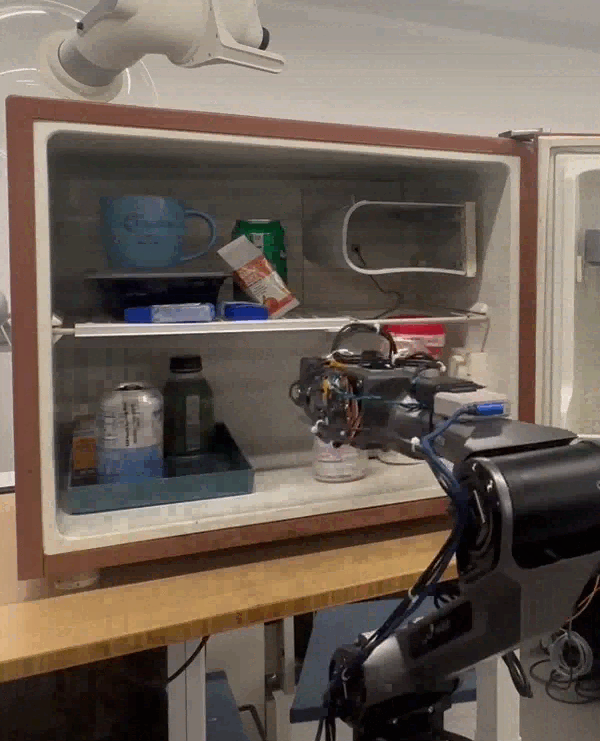
DexWrist enables constrained-space manipulation

Fridge Pick

Demonstration (1x Speed)

Cable Unplug

Demonstration (1x Speed)

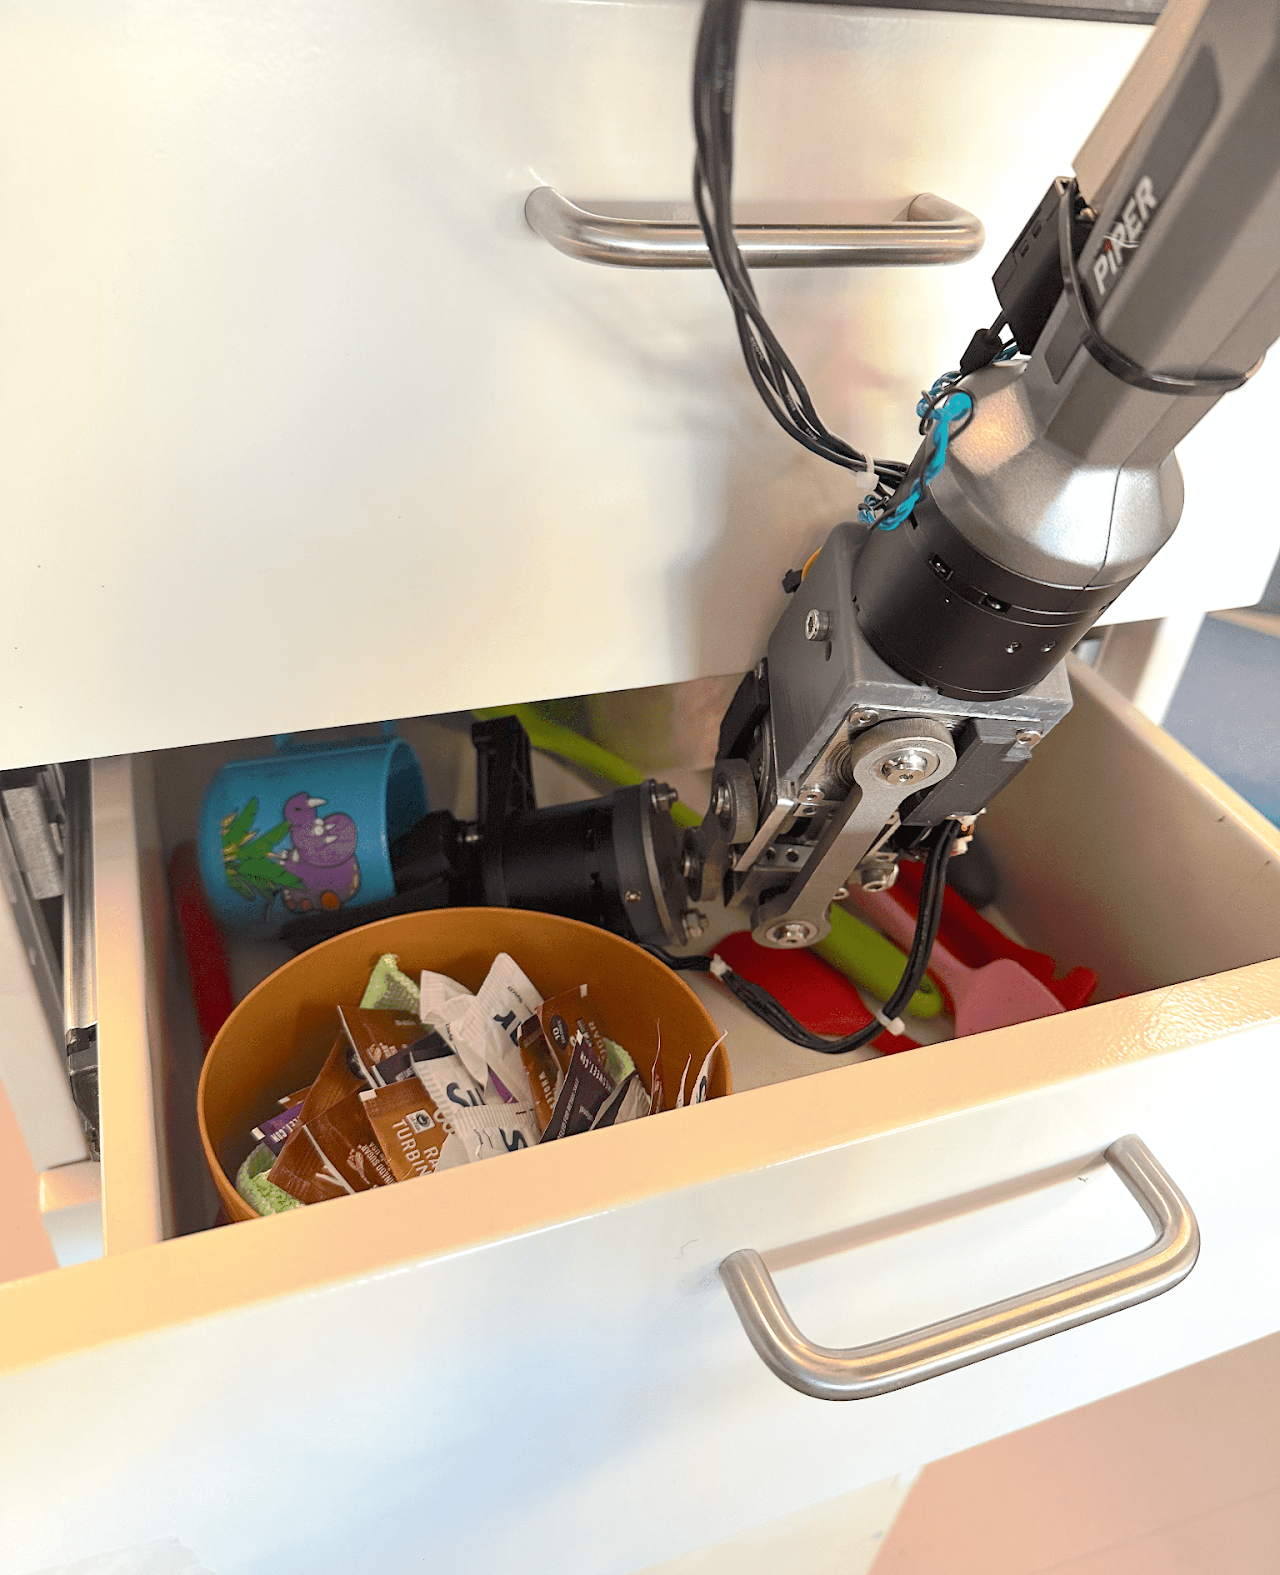
Drawer Pick

Demonstration

(1X Speed) DexWrist enables manipulation in constrained spaces where traditional wrists fail.

Why DexWrist?

  • Enables constrained, dynamic manipulation tasks on any robot arm
  • Torque transparency and easily simulatable kinematics enables dynamic policy learning
  • Facilitates faster teleoperation for more scalable data collection
  • Reduces trajectory lengths, making policy learning more efficient

Decoupled Parallel Kinematic Mechanism

A novel 2-DOF Parallel Kinematic Mechanism (PKM) achieves co-located pitch and yaw DOFs while maintaining a diagonal velocity-constraint Jacobian, a one-to-one motor-to-DOF mapping at the constraint level (full derivation). This improves constrained space performance by reducing arm movement needed for end effector rotation and provides more intuitive teleoperation. The final DOF is achieved by mounting the wrist to an arm.

Quasi-Direct Drive Actuators
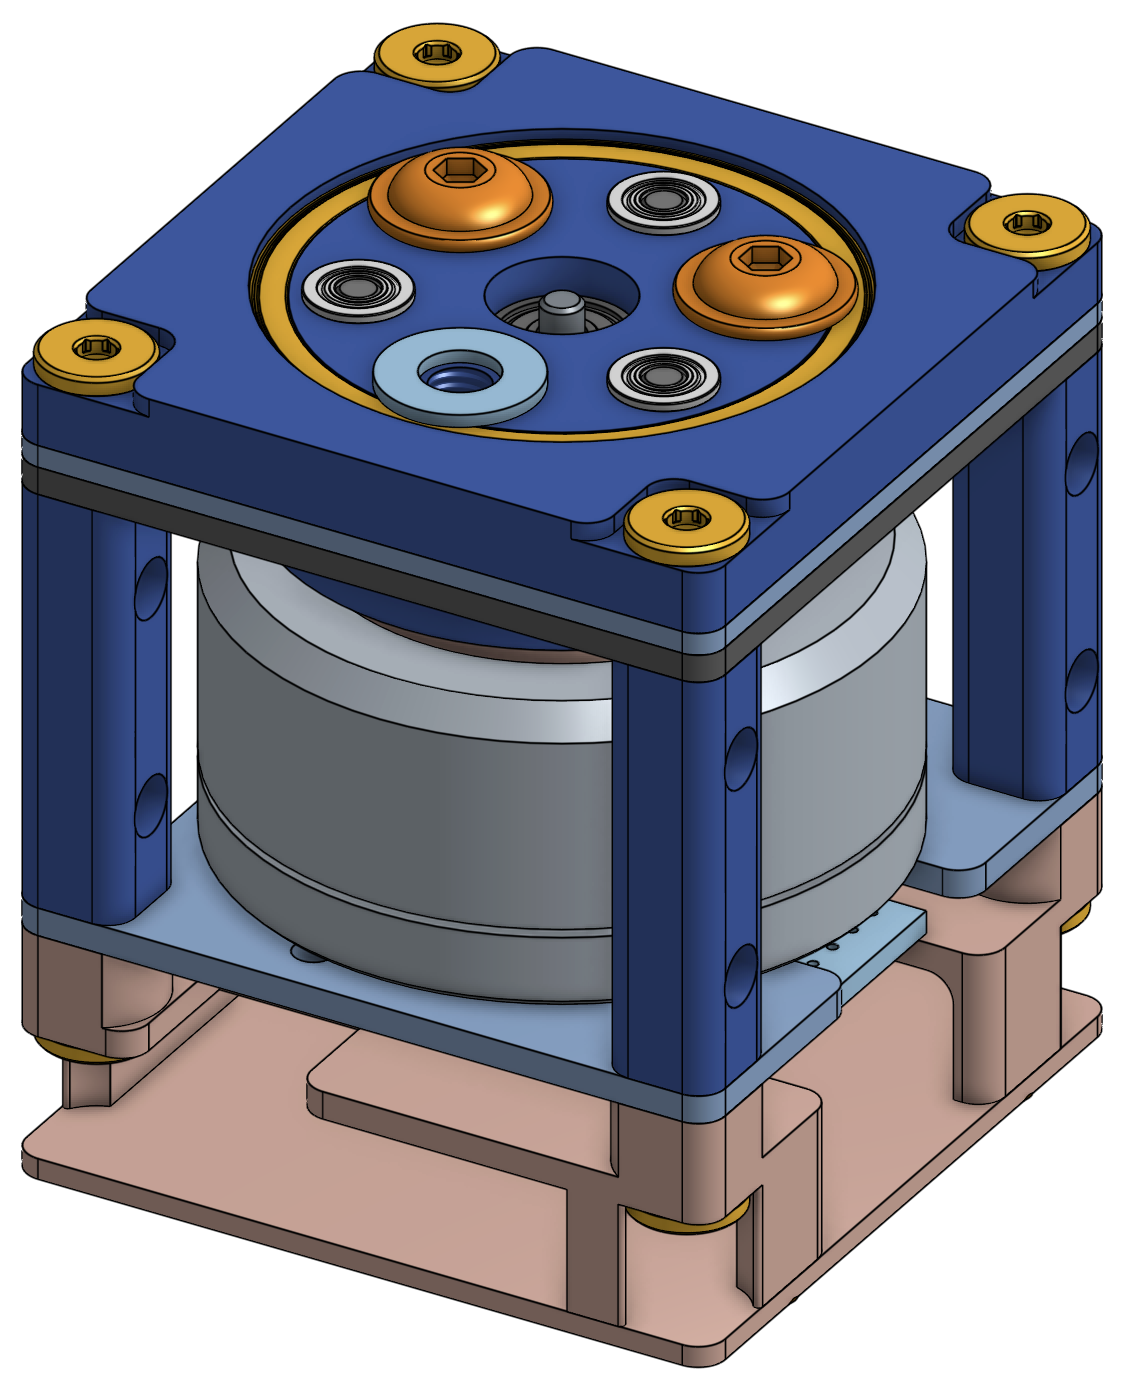
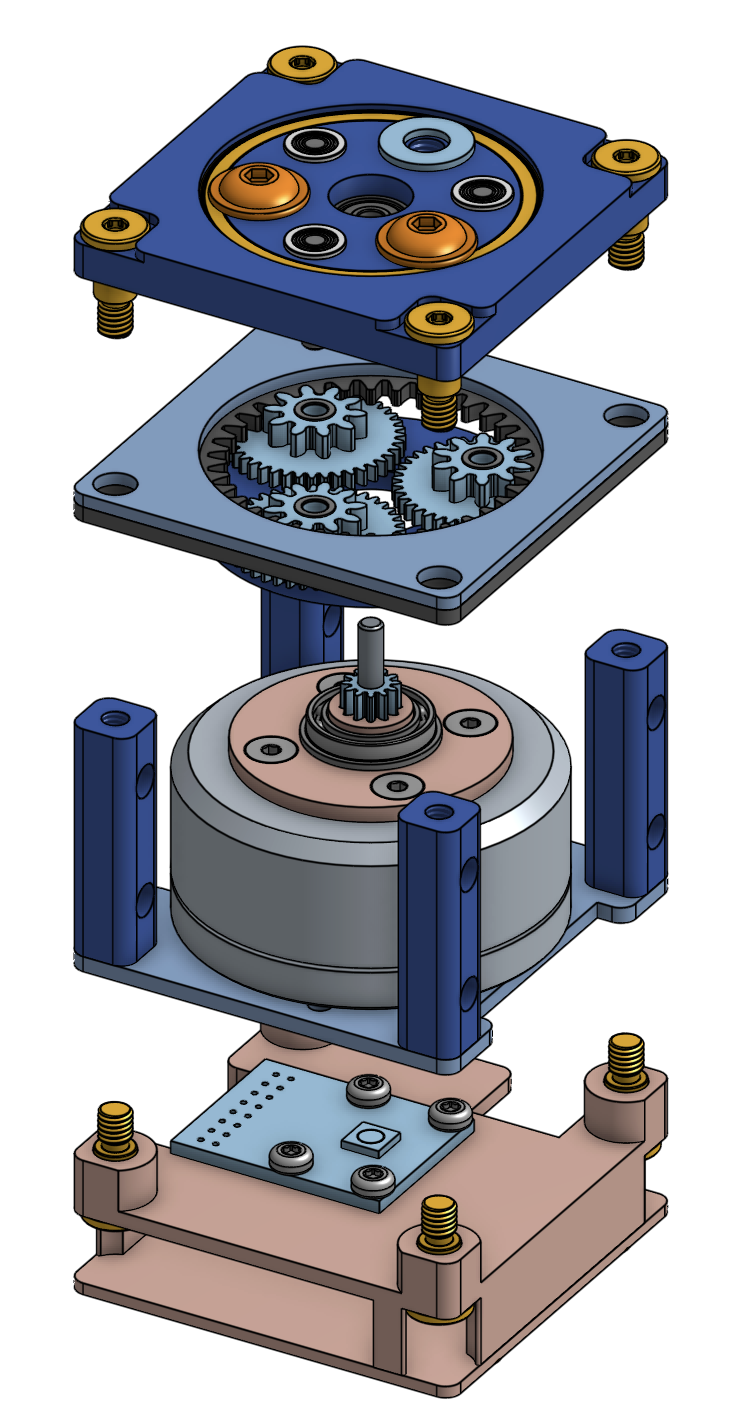
Assembled quasi-direct-drive actuator Exploded view of the planetary gearbox

Custom Quasi-Direct Drive (QDD) actuators with brushless motors and a 13:1 planetary gearbox allows for dynamic tasks due to its backdriveability and speed, much how humanoid robots achieved dynamic movement using such actuators.

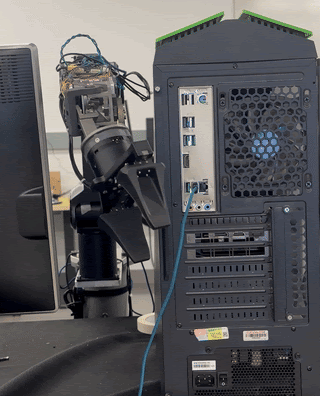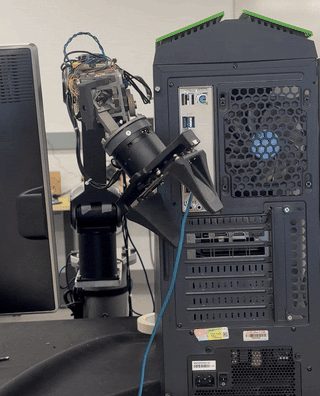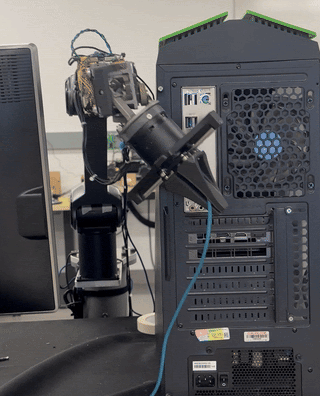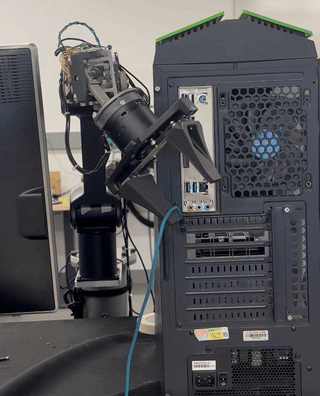
DexWrist exhibits co-located DOFs similar to the human wrist, which is a condyloid/ellipsoidal joint.

[1x Speed] DexWrist has a large workspace and fits on most commercial robotic arms (AgileX shown). This makes fast, dynamic tasks possible on any arm.
Mechanical Validation

Functional requirements and measured performance. Spec denotes the design target derived from cited work. ROM spec denotes minimum coverage and can be exceeded.

Requirement Spec Ours Meets
Rated torque (Nm) ≥ 3 3.75 ± 0.05
Backdrive torque (Nm) ≤ 0.4 0.33 ± 0.06
Hardstop load cap. (Nm) ≥ 9 ≥ 14
Axial load cap. (kg) ≥ 15 ≥ 100
No-load speed (rpm) ≥ 53.3 96.6 ± 9.4
Torque BW (Hz) @ 3.75 Nm ≥ 10 10.15 ± 1.34
Angular precision (deg) ≤ 3.47 1.65
F/E ROM (deg) [−40°, 40°] [−40°, 40°]
R/U ROM (deg) [−10°, 30°] [−40°, 40°]
Width (mm) ≤ 61.4 64
Height (mm) ≤ 61.4 66.5
Length (mm) ≤ 195.5 178.2
Weight (kg) ≤ 1.0 0.97

Load capacity values are tested-to values that were loaded to without failure. DexWrist provides F/E and R/U only; P/S is assumed upstream. Width and height exceed the anthropometric target by only 4% and 8%, respectively, due to the driving links.

System-Level Evaluation

DexWrist augments a robot arm along two axes. Its decoupled parallel kinematic mechanism co-locates the wrist degrees of freedom, reducing the arm motion required to reorient the end-effector in constrained spaces. Its quasi-direct-drive actuation lowers mechanical impedance, stabilizing contact without finely tuned admittance control.

We evaluate each contribution on an arm limited along the corresponding axis. Constrained-space tasks on the AgileX PiPER, whose spaced serial joints demand large arm motions for small reorientations, assess the kinematic contribution; dynamic wiping on the UR3e, whose stiff harmonic drives impede contact, assesses the actuation contribution.

We then repeat the wiping evaluation on a torque-controlled Franka FR3, whose high-quality joint-impedance control already performs the task well, to determine whether the improvement persists against a strong compliant-control baseline.

Reachability Experiment

Assessing the kinematic contribution on the AgileX PiPER

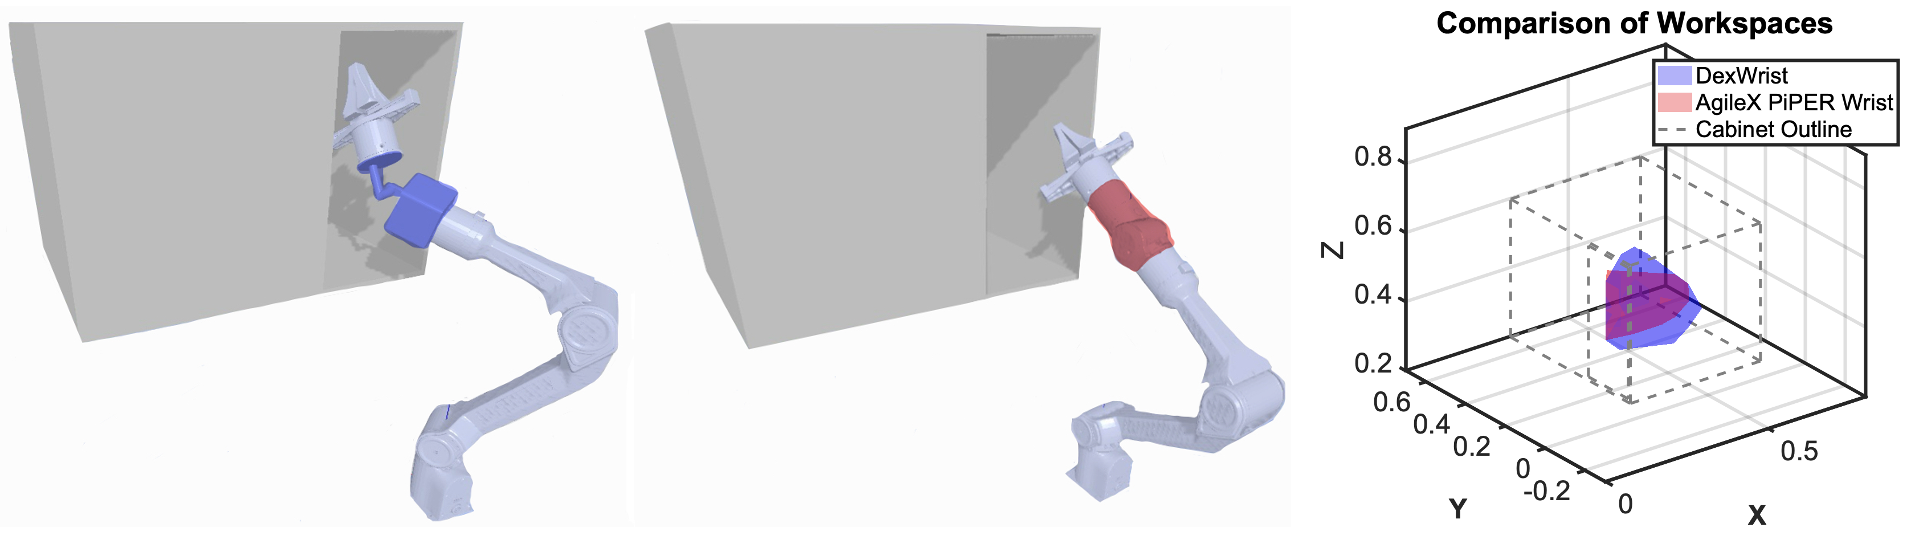
We compared the reachable workspace of the stock AgileX PiPER against the AgileX PiPER with DexWrist in a simulated kitchen cabinet reaching task.

Target points were uniformly sampled inside the cabinet volume in PyBullet. Each point was tested for a collision-free inverse kinematics solution (robot self-collision and cabinet collision).

Workspace comparison between stock AgileX wrist and DexWrist

DexWrist increased the number of reachable targets by 88% over the stock serial wrist.

The stock wrist fails primarily at targets deep inside the cabinet and near the walls, where the serial joint layout forces self-collisions or cabinet collisions.

Teleoperation User Study

Shorter demonstrations and reduced operator effort across the constrained AgileX tasks and contact-rich wiping

Metric Task Base DexWrist
Operator
Time (s)
Fridge 63.5 38.7
Wipe (UR3e) 21.5 6.6
Wipe (Franka) 24.2 22.4
Cable 76.3 28.0
Drawer 57.2 29.6
Resets Fridge 1.7 1.0
Wipe (UR3e) 0.2 0.0
Wipe (Franka) 0.2 0.0
Cable 0.6 0.4
Drawer 0.6 0.3

Fewer environment resets required and less overall human teleoperator time in constrained spaces.

DexWrist’s co-located DOFs and low-impedance actuation yield shorter demonstrations in constrained and contact-rich tasks. 1.3–2.2× shorter individual demonstrations on the AgileX and UR3e tasks; 1.2× on the Franka wiping comparison, where the strong baseline leaves less to improve.

Policy Learning Results

Behavior-cloning success on the constrained AgileX task and the contact-rich UR3e task

DexWrist achieved 50–76% relative improvement in policy success rates on the AgileX and UR3e


Wiping Under a Strong Compliant-Control Baseline

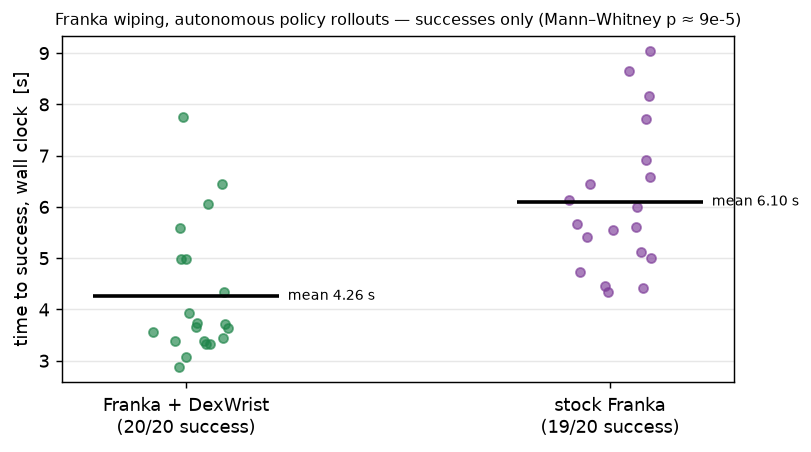
To confirm that the wiping improvement reflects the wrist hardware rather than the UR3e's admittance controller, we repeat the evaluation on a torque-controlled Franka FR3, whose joint-impedance control already performs the task well. Success is saturated for both conditions (stock 19/20, DexWrist 20/20), so completion time is the informative metric: with DexWrist, the policy completes the task 1.43× faster under the same controller and action space.

Franka wiping completion times, DexWrist vs stock

Full experiment, including the teleoperation-effort comparison, on the Franka wiping page.

Autonomous Task Completion

Diffusion policies trained for DexWrist reduced task completion times by 3–5× on the AgileX PiPER and UR3e, and 1.4× on the torque-controlled Franka FR3

System Policy Task Completion Time (s)
Mean ± SD Min Max
AgileX + stock wrist 91.0 ± 7.9 55.2 134.2
AgileX + DexWrist (Ours) 28.1 ± 2.2 20.5 49.0
UR3e + stock wrist 21.2 ± 10.5 12.7 40.6
UR3e + DexWrist (Ours) 4.3 ± 1.2 1.9 6.5
Franka FR3 + stock wrist 6.1 ± 1.4 4.3 9.0
Franka FR3 + DexWrist (Ours) 4.3 ± 1.3 2.9 7.8

The AgileX + DexWrist completed the constrained pick-and-place task 3.24× faster, and the UR3e + DexWrist completed the dynamic wiping task 4.92× faster than the default configurations. On the Franka FR3, whose high-quality joint-impedance baseline already succeeds at wiping, DexWrist completed the task 1.43× faster with the same controller and action space (full experiment).

Statistics over successful trials at each system's best checkpoint (N ≥ 15 per system).

Supplementary Material

Full derivations, protocols, and per-trial data referenced by the paper.